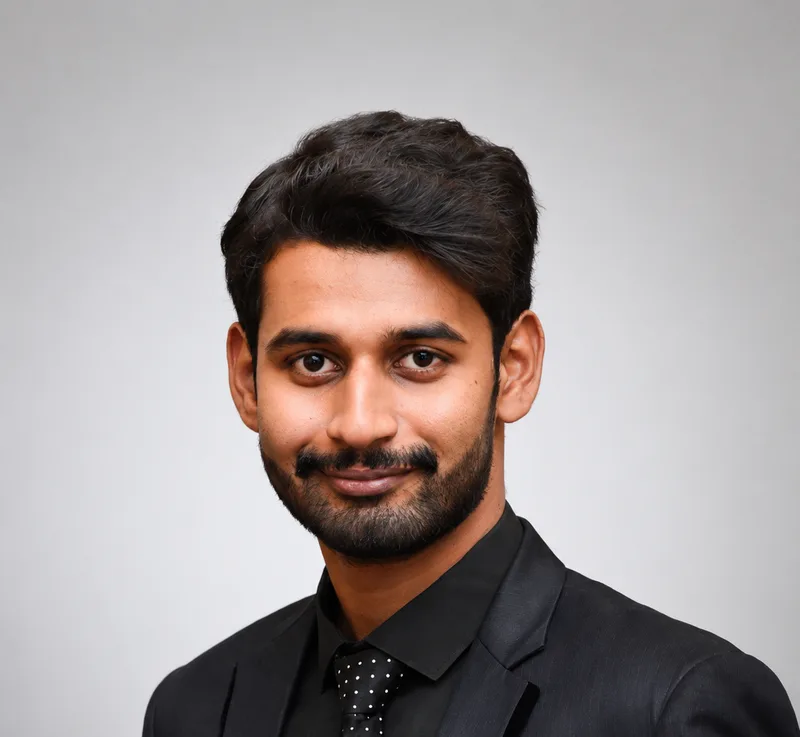
Open for Robotics, Embedded & Firmware Roles · Paid Trial Tasks Welcome·Faisalabad, Pakistan
Engineering Robotics & Autonomous Systems
>
Mechatronics and Control Engineering student with three industrial internships and hands-on robotics and embedded projects. I build closed-loop control systems end to end: CAD and simulation first, then ESP32, ARM and Raspberry Pi hardware. My AGV automation proposal at FESCO was approved by the Manager and Deputy Director, and the Director asked for me by name to lead the hardware implementation. Looking for an early-stage robotics, embedded or firmware role.
Muhammad Riyan
B.Sc. Mechatronics & Control Engineering @ UET Lahore (Final Year)
3 Completed
Industrial Internships
8+ Builds
Technical Projects
FESCO Approved
AGV Proposal
UET Lahore
University
LIVE BLOGGER FEED
Technical Writing & Engineering Insights
Deep dives on Edge AI, Embedded Microcontrollers, Robotics, and Real-Time Systems.
A deep dive into running real-time vision pipelines on constrained hardware, exploring quantized neural networks, memory optimization, and embedded ESP32 deployment.
Bridging the gap between mathematical model formulation and embedded execution. Step-by-step workflow for model compression, fixed-point quantization, and C++ inference engines.
Why latency, privacy, and power efficiency are pushing artificial intelligence to edge silicon. Exploring Neural Processing Units (NPUs) and real-time inference on bare metal.
Designed and built a functional 3-DOF RRP robotic manipulator for industrial sorting applications, derived from kinematic principles through to a physical 3D-printed build with ESP32 motion control.
Closed-loop PID control system designed and deployed on an ESP32 microcontroller with an L298N driver and quadrature encoder for precise motor speed and position tracking.
⚡ Simulate-Before-Deploy⚡ Quadrature Encoder Feedback⚡ CEA Benchmarked
ESP32L298N Motor DriverQuadrature EncoderMATLAB/SimulinkPID Control
embedded FEATURED
Speed Control & Visualization with IR Sensors & OLED
Real-Time Embedded Data Acquisition & Display Pipeline
Embedded signal processing system for non-contact rotational speed measurement and live on-device visualization using infrared sensors and an OLED screen.
Palm-sized autonomous micro-drone built from first principles, featuring a 3D-printed lightweight airframe, custom circuit integration, and ESP32 flight stability firmware.
ESP32Embedded C++Sensor Fusion3D-Printed AirframeSolidWorksPID Control
robotics
Autonomous Line-Following Robot
IR Sensor Array · PID Control · UET Lahore Competition 4th Place
ESP32-based autonomous line-following robot with IR sensor array and PID control, built in a single day and placed 4th at UET Lahore inter-university robotics competition.
⚡ Built in a Single Day⚡ 4th Place at UET Lahore Competition⚡ PID Differential Steering
ESP32IR Sensor ArrayC/C++PID ControlDC Motor Driver
control-systems FEATURED
Inverted Pendulum (Cart-Pole)
Dual-Encoder Cascaded PID · Arduino & Python
Classic control-theory benchmark: a cart-pole inverted pendulum with dual-encoder feedback and cascaded PID control loops implemented on Arduino with Python telemetry.
Python Desktop GUI Application with Non-Blocking UI
Multi-threaded Python application featuring a custom Tkinter GUI for splitting large media files into user-defined segments without freezing the user interface.
4-motor AGV skid-steer, hook-and-fork mechanism, robotic arm assemblies, URDF export
MATLAB / Simulink
3 Years Production
92%
Control-loop design, transfer function derivation, simulate-before-deploy pipeline
Python Engineering
3 Years Production
90%
ROS2 nodes, telemetry, multi-threaded GUI apps, data processing
KiCAD & Hardware Design
2 Years Production
82%
PCB schematic capture and layout for embedded projects
NODE INSPECTOR HUD
Tap or hover over any skill card to inspect detailed metrics & project affiliations.
INDUSTRIAL EXPERIENCE & IMPACT
Industrial Internships & Engineering Roles
Hands-on experience across power generation plant control, chemical process automation, and FESCO printer AGV fleet automation.
Automation Engineering Intern
CURRENT
FESCO (Faisalabad Electric Supply Company) — Machine Room
2026
Faisalabad, Pakistan
AGV Proposal Approved by Director9.5/10 Supervisor RatingROS2 Jazzy Architecture
>Designed a phased AGV automation proposal to replace manual paper-tray refilling on HP LaserJet printers (11 printers, batches of 140–150k prints); the proposal and Phase 1 budget were approved by the Manager and Deputy Director.
>Engineered the Phase 1 AGV prototype: 4-motor skid-steer drive, hook-and-fork tray mechanism, Raspberry Pi 5 with camera, and ArUco-marker docking to a removable printer cassette.
>Built the ROS2 Jazzy architecture (line-following, vision, lift, hook and state-machine nodes) and a SolidWorks→URDF→Gazebo simulation pipeline, with MATLAB/Simulink for control-loop design.
>Wrote the system handover manual and parts sourcing list so FESCO staff can build, service and extend the hardware.
>Rated 9.5/10 on the supervisor feedback form; the Director asked for me by name to lead the hardware implementation.
ROS2 JazzyRaspberry Pi 5ArUco VisionSolidWorksGazeboMATLAB/SimulinkURDF
Ibrahim Fibres Limited (Industry 4.0 Textile Plant)
2025
Faisalabad, Pakistan
HR Career ApproachPower Plant & Instrumentation RotationIndustry 4.0 Exposure
>Rotated through the power plant (safety relays, PLC, SCADA, DCS, VFDs), instrumentation (P&IDs, PT100, ultrasonic, nuclear and float level sensors) and electrical (plant motors) departments.
>Gained direct exposure to high-availability industrial control systems in a continuous-process Industry 4.0 manufacturing environment.
>Approached directly by HR about a future career with the company.
PLCSCADADCSVFDsPT100P&IDsLevel Sensors
VERIFIED QUALIFICATIONS
Certifications & Credentials
Specialized engineering accreditations in machine vision, CAD mechanical design, structured problem solving, and AI engineering.
Structured Problem Solving Certification
Hyundai Pakistan × UET Lahore • 2026
Certified in structured engineering problem-solving methodologies for industrial systems.
ID: HYUNDAI-UET-2026
Structured Problem SolvingRoot Cause AnalysisEngineering Reliability
CPD: Machine Vision Certification
Continuing Professional Development (CPD), UET Lahore • 2026
Professional development certification in industrial machine vision and automated optical inspection.
ID: CPD-MV-2026
Machine VisionImage ProcessingFeature Extraction
CPD: SolidWorks 3D CAD Design
Continuing Professional Development (CPD), UET Lahore • 2024
Certification in advanced mechanical design, part assemblies, and CAD modeling for robotics.
ID: CPD-SW-2024
SolidWorks3D ModelingURDF Kinematic Assemblies
AI/ML Engineering Bootcamp
UET Lahore • 2023
Intensive engineering bootcamp covering machine learning algorithms and data analysis fundamentals.
ID: AIML-UET-2023
PythonAI/ML FundamentalsData Processing
Anthropic AI Fluency Certifications
Anthropic AI • 2026
Certifications spanning Claude 101, Claude Code 101, and the AI Fluency Framework for AI-assisted engineering.
ID: ANTHROPIC-AI-101
Claude 101Claude Code 101AI Fluency Framework
INDUSTRY ENDORSEMENTS
Professional Recommendations
Formal endorsements from industrial plant managers, senior engineers, and internship supervisors.
Ibrahim Fibres Plant Engineering Team
Power Generation & Control Manager
Ibrahim Fibres Limited (IFL) • 2025
"Muhammad Riyan demonstrated high technical competence and structured problem-solving while observing control loops and instrumentation in our power generation plant."
Supervised Riyan during Power Generation Instrumentation Internship
Sitara Chemicals Automation Team
Lead Automation Engineer
Sitara Chemicals • 2025
"Riyan took a proactive approach to mastering PLC ladder logic programming and troubleshooting electronic control valves on the active chemical production floor."
Supervised Riyan on PLC Ladder Logic & Sensor Calibration
TESTIMONIALS & FEEDBACK
Supervisor & Peer Feedback
Faculty Feedback
"Riyan is an outstanding mechatronics student whose 3-DOF RRP sorting arm manipulator was selected for live demonstration before an industrial delegation at our FYP exhibition."
Faculty of Mechatronics & Control Engineering
Department Supervisor • UET Lahore (Faisalabad Campus)
INTERACTIVE CONTROL & TESTING LAB
Mechatronics CLI & Physics Sandbox
Execute engineering commands in the interactive terminal or tune system response dynamics, spring constants, and damping parameters in real time.
muhammad-riyan-cli:~
ONLINE
>init
Welcome to Muhammad Riyan CLI v2.4. Type "help" to view available engineering commands.
INITIATE CONTACT
Let’s Build Something Extraordinary
Whether you are offering a Robotics / Embedded / Firmware role, discussing a paid trial task, or consulting on industrial automation — send a message below.